Half-day workshop · iSpaRo/iSAIRAS 2026
Open Space Robotics: Software and Hardware Solutions
A working session for the orbital and planetary robotics community building open-source, openly documented software and hardware.
- Date
- 5th November
- 9:30 to 13:00
- Attendance
- In-person: Room T
- Zoom Webinar:
- Deadline
- Submission: 21st October
- Results: rolling, 22nd Oct.
Our goal: to create a collaborative and open ecosystem for space robotics that promotes replicable, reliable, and benchmarkable research.
The space robotics community has historically been constrained by proprietary, siloed, and hard-to-reproduce software and hardware stacks, which slows down research progress and makes it difficult for new groups to enter the field. This workshop brings together researchers, engineers, and practitioners working on open-source and openly documented solutions for orbital and planetary robotics, to foster a more collaborative, reproducible, and accessible ecosystem.
Our objective is twofold: i) to showcase tools such as simulation frameworks, autonomy stacks, SITL/HITL pipelines that are publicly released and usable by the broader community; ii) to identify gaps and opportunities for collaboration across groups currently developing similar tools in isolation. We aim at creating a community to promote open-source in the space robotics domain.
Discussion topics
Simulation frameworks for orbital and planetary robotic systems
Publicly released frameworks for guidance, navigation, and control
Hardware robotic solutions toward democratized space robotics testbeds
Digital twins for realistic orbital and planetary robotics emulation
Software-in-the-loop and hardware-in-the-loop software solutions
Operating systems, schedulers, and fault-tolerant solutions
Open benchmarks for space robotics
Hardware-accelerated implementations on GPUs, DSPs, and NPUs via CUDA, OpenCL, OpenVINO, and more
Continuous integration pipelines for testing space software over many simulated flight hours
Invited speakers & panelists - To be announced
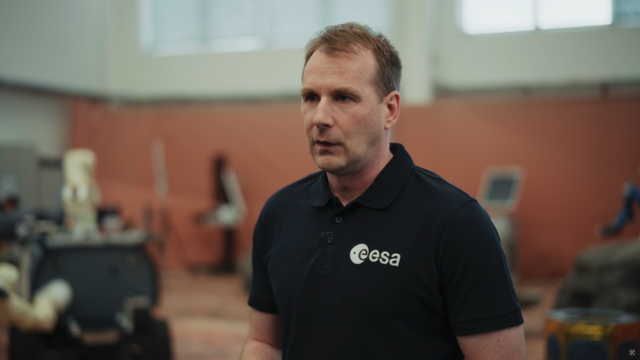
Keynote 1
Thomas Krüger
ISS payload and qualification with (mostly) open-source software
Keynote 2
Hrishik Mishra
Model-based Control Design for Orbital Robotics Missions
Keynote 3
To be announced
Submission instructions
Contributions are accepted in one of two formats. Pick whichever shows your best!
-
PDF POSTER
An A0 poster of your work, submitted as a single PDF. Accepted poster submissions will be displayed in the workshop room during the session, and we encourage you to prepare 1-2 slides for the Spotlight Pitch!
-
2MIN VIDEO
A two-minute video detailing your contribution. Accepted video submissions will be showcased during the Spotlight Pitch. Make sure to bring a laptop/tablet to play your video during the showcase.
-
HARDWARE DEMO
We will showcase hardware demos during the Open Area Demonstrations. Make sure to mark if you wish to bring a demo when submitting your contribution on Open Review.
Submission Portal: OpenReview Submission Page. Submission deadline: October 21, 2026 Notification of acceptance: October 22, 2026
Note: accepted submissions have to be presented by a registered author. Please ensure that at least one author registers for the workshop to present the contribution. See the section Participation & logistics for more details.
Schedule
-
Opening remarks
-
Keynote 1: "ISS payload and qualification with (mostly) open-source software", Thomas Krüger, ESTEC, ESA.
-
Keynote 2: "Model-based Control Design for Orbital Robotics Missions", Hrishik Mishra, DLR-RM.
-
Keynote 3:
-
Panel Discussion
-
Spotlight Pitches (1min each)
-
Coffee Break / Open Area Demonstrations
-
Open Area Demonstrations
-
Closing remarks
Participation & logistics
To participate in the workshop, a registration to i-SAIRAS/iSpaRo is required. Please follow the conference registration page to register. Remote participation is available for the public (non-registered/non-participating attendees).
Remote participation
Zoom participation will be available for keynote talks, panel discussion and spotlight pitches.
Demonstration area
An area for demonstrations of open source hardware and software, promoting interaction with the community.
Poster Showcase
Contributions will be displayed in a dedicated area, allowing attendees to engage with the authors and discuss their work.